# Google tests Gemini Robotics 2.5 in Mercedes factories
> Apollo's parts-sorting pilot leaves reliability questions unanswered.
By BIGCHANGE.AI Editorial
Published: 2026-11-10T20:52:38.904Z
Updated: 2026-11-10T20:52:38.904Z
Canonical: https://bigchange.ai/blog/gemini-robotics-apollo-factory-kitting
AI-generated conceptual illustration for BIG CHANGE
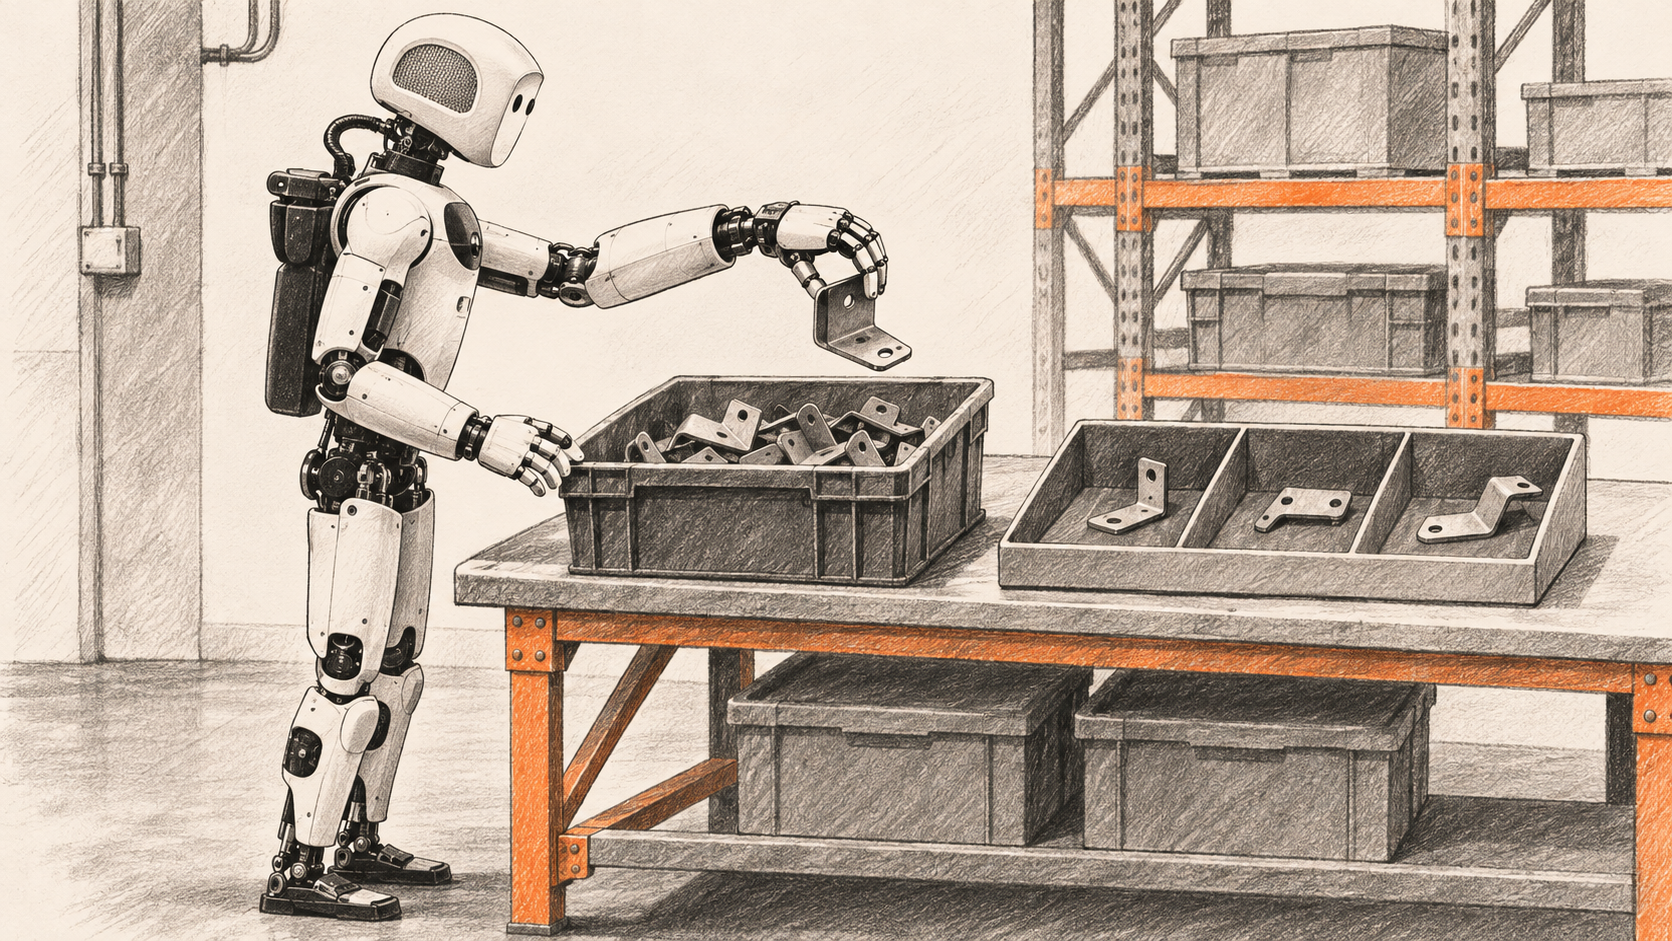
Google DeepMind announced Gemini Robotics 2.5 on November 10, reporting a Mercedes-Benz factory proof of concept with Apptronik's Apollo 2 humanoid.
## The big change
- Google reports 96% success sorting metal brackets from bulk bins into sequencing containers on active production lines. Its embodied reasoning model tracked workflow, while Robotics 2.5 controlled hands and arms and corrected gaps.
- Planning and movement are different jobs. Google's July model introduction described an embodied reasoning model that observes a scene, plans steps and tracks progress, paired with an action model that converts vision and language into motor control.
- A success percentage needs a defined unit. Completing one pick and completing an entire kit are different measures; factory operators also need to know whether errors require someone to stop work and intervene.
## What a robot must do with a part
In automotive kitting, a collection of part variants is assembled for an individual car. A [2018 research paper](https://arxiv.org/abs/1809.05380) describes the practical stages: detect containers, distinguish parts, recognize the required variant, generate a grasp and plan the arm's movement. Each stage solves a different problem. Recognizing the right component does not itself determine how to grip it or move it safely.
That study's KittingBot used a mobile base and manipulator, with people collecting some parts and the robot collecting others. Its evaluation included recognizing variants and avoiding unforeseen obstacles. This is an earlier, different system, not independent validation of Apollo. It illustrates why a useful kitting assessment must examine physical handling and the surrounding workflow, rather than only whether software can name the next step.
## What the factory result leaves open
The [trial](https://deepmind.google/blog/gemini-robotics-2-5-accelerates-real-world-physical-intelligence/) took place in Kecskemét, Hungary, and Sindelfingen, Germany. Google does not disclose the success unit, attempt count, duration or intervention rate. BIG CHANGE has not independently reproduced the result.
The missing conditions prevent translating the reported percentage into an established full-shift reliability figure or a deployment at scale.
[Apptronik's March 2024 agreement](https://apptronik.com/news-collection/apptronik-and-mercedes-benz-enter-commercial-agreement) with Mercedes already envisaged logistics work: bringing assembly kits to workers, inspecting components and delivering containers of prepared parts. Those were identified applications to explore. An agreement or a list of intended jobs is not, by itself, a measured record of continuous production.
## Access is not the same as readiness
Robotics 2.5 is rolling out to partners; Google does not announce general public access.
The [July introduction](https://deepmind.google/blog/gemini-robotics-2-brings-whole-body-intelligence-to-robots/) separately offered embodied reasoning through Google AI Studio and a Cloud private preview, while action models went to early-access partners. Those are different models and access routes: availability of a planning interface does not establish availability of every motor-control model.
Google also announced ASIMOV-Jailbreak to test disguised unsafe requests. Such a benchmark does not certify physical safety. The linked [dataset page](https://huggingface.co/datasets/google/asimov_agentic) requires login and information-sharing conditions for its files; BIG CHANGE did not access them.
For a buyer, the next useful evidence is operational: attempted work, error recovery, human assistance and performance around people over time. Tests should match the parts and workflow the buyer actually needs. Resistance to unsafe instructions is a separate question from whether an installed machine can operate safely alongside workers.
## Sources
- [Google DeepMind Robotics 2.5 announcement](https://deepmind.google/blog/gemini-robotics-2-5-accelerates-real-world-physical-intelligence/) — Company account of the pilot and rollout.
- [Automotive collaborative kitting research](https://arxiv.org/abs/1809.05380) — Earlier explanation of vehicle-specific parts kitting.
- [Apptronik and Mercedes 2024 agreement](https://apptronik.com/news-collection/apptronik-and-mercedes-benz-enter-commercial-agreement) — Earlier logistics exploration.
- [Google DeepMind Robotics 2 introduction](https://deepmind.google/blog/gemini-robotics-2-brings-whole-body-intelligence-to-robots/) — Earlier reasoning and action-model distinction.
- [Google ASIMOV Agentic dataset page](https://huggingface.co/datasets/google/asimov_agentic) — Public page describes evaluation; files require conditions.
The BIG CHANGE newsletter
The big picture. At your pace.
Recent stories on AI and robotics, the shifts worth watching and practical ideas to use. Choose a daily briefing, weekly digest or monthly perspective.
Next scheduled send (UTC): . Your first edition arrives at the next scheduled send after you confirm.
Your privacy, your choice.
Necessary storage supports site security and remembers your choices. Optional Google Analytics stays off until you allow it. You can read every story with necessary storage only. Privacy details