# GelSlim 5.0 switches one fingertip camera between vision and touch
> Paired images reduce depth error on known objects.
By BIGCHANGE.AI Editorial
Published: 2026-10-25T05:06:38.363Z
Updated: 2026-10-25T05:06:38.363Z
Canonical: https://bigchange.ai/blog/gelslim-5-fingertip-camera-vision-touch
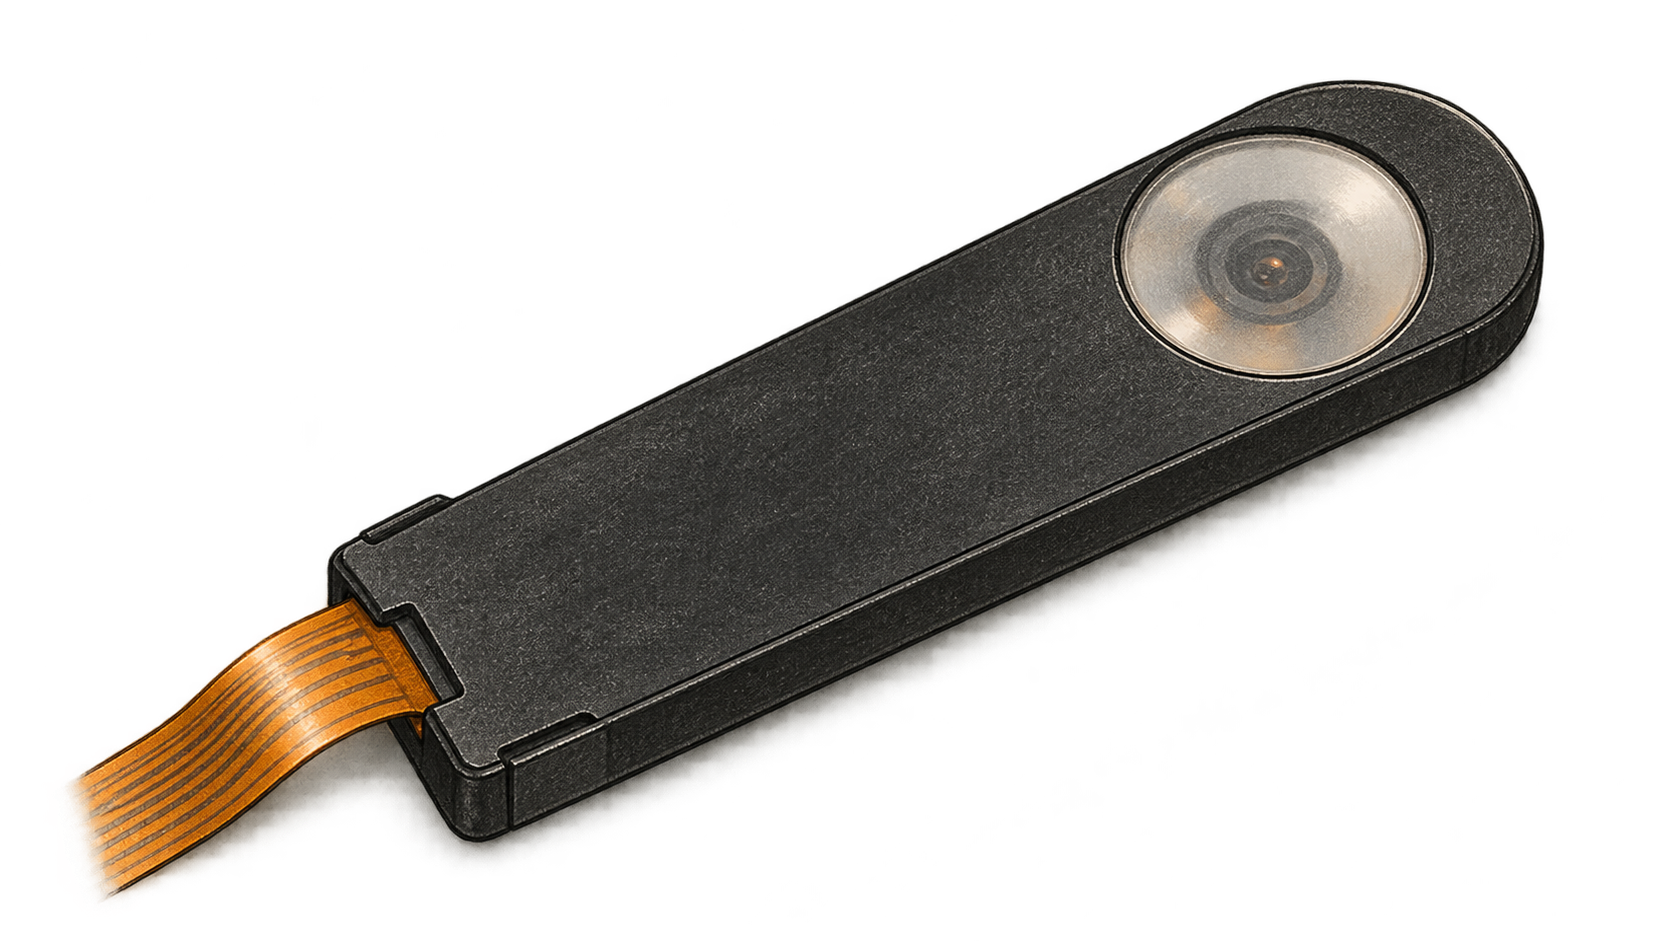
AI-generated conceptual illustration by BIG CHANGE, informed by the authors’ sensor figures; not documentary imagery or an independently tested device.
[GelSlim 5.0](https://arxiv.org/html/2610.31334v1) captures UV-off object views and UV-on contact images sequentially under near-stationary contact.
## The big change
- **What changed:** The lab's [GelSlim 4.0](https://www.mmintlab.com/research/gelslim-4-0/) focused on touch; 5.0 adds a visual state.
- **Why it matters:** VisTacFusion combines views for pose and depth.
- **What to watch:** Validation used known objects within sessions.
## What the paired result measures
The [table](https://arxiv.org/html/2610.31334v1) reports depth mean squared error of 0.0066 mm² with paired inputs versus 0.0170 mm² with touch alone, 61.2% lower. One geometry checkpoint served both modes.
Researchers logged about 400 contacts per object across 12 known objects, reserving every tenth session sample for validation and checkpoint selection. Pose queries used object identity; depth targets came from geometry and pose, not membrane measurement. New-object and cross-session results are unreported.
The public [GelSlim 4.0 hardware repository](https://github.com/MMintLab/gelslim_hardware) contains predecessor design files. It does not establish a version 5.0 release. A version 5.0 project page did not resolve during our check; its code, data, hardware files, access terms and cost remain unverified.
## Sources
- [GelSlim 5.0: Unifying Vision and Touch with a Single Fingertip Camera](https://arxiv.org/html/2610.31334v1) — Author paper Sections III to V and Tables II and III establish the prototype construction, VisTacFusion, validation design and author-reported errors. It does not demonstrate deployed manipulation, unseen-object accuracy or independent replication.
- [GelSlim 4.0: Focusing on Touch and Reproducibility](https://www.mmintlab.com/research/gelslim-4-0/) — The lab describes the prior tactile sensor and links manufacturing, design, depth and shear resources. This does not establish GelSlim 5.0 availability.
- [GelSlim 4.0 Hardware Files](https://github.com/MMintLab/gelslim_hardware) — Contains version 4.0 sensor body, assembly, gel mold and electronics file links. It is predecessor context, not a version 5.0 release.
The BIG CHANGE newsletter
The big picture. At your pace.
Recent stories on AI and robotics, the shifts worth watching and practical ideas to use. Choose a daily briefing, weekly digest or monthly perspective.
Next scheduled send (UTC): . Your first edition arrives at the next scheduled send after you confirm.
Your privacy, your choice.
Necessary storage supports site security and remembers your choices. Optional Google Analytics stays off until you allow it. You can read every story with necessary storage only. Privacy details