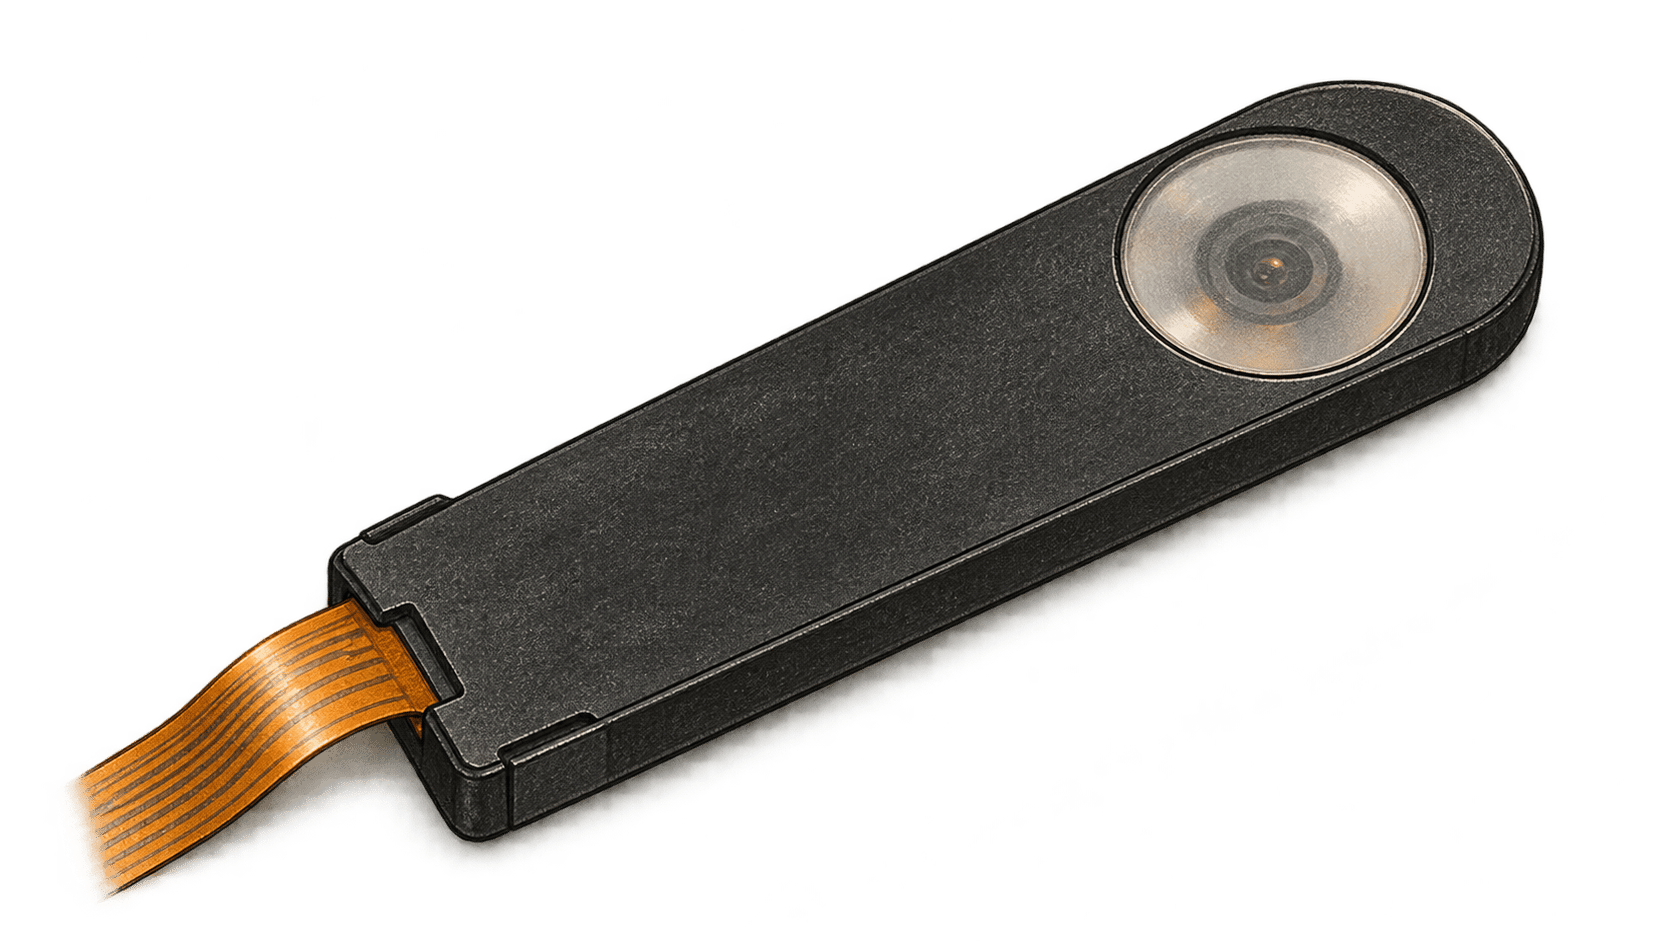
GelSlim 5.0 captures UV-off object views and UV-on contact images sequentially under near-stationary contact.
The big change
- What changed: The lab's GelSlim 4.0 focused on touch; 5.0 adds a visual state.
- Why it matters: VisTacFusion combines views for pose and depth.
- What to watch: Validation used known objects within sessions.
What the paired result measures
The table reports depth mean squared error of 0.0066 mm² with paired inputs versus 0.0170 mm² with touch alone, 61.2% lower. One geometry checkpoint served both modes.
Researchers logged about 400 contacts per object across 12 known objects, reserving every tenth session sample for validation and checkpoint selection. Pose queries used object identity; depth targets came from geometry and pose, not membrane measurement. New-object and cross-session results are unreported.
The public GelSlim 4.0 hardware repository contains predecessor design files. It does not establish a version 5.0 release. A version 5.0 project page did not resolve during our check; its code, data, hardware files, access terms and cost remain unverified.