Bao and colleagues' October 22 preprint Not an Accident reports arm collisions in seven selected humanoid safety-filter trials.
The big change
- What changed: A task change preceded arm contact despite filtering.
- Why it matters: A formal safety rule applies only where its assumptions hold and a feasible correction exists. A filter name alone does not establish physical clearance through changing tasks.
- What to watch: Systematic physical trials across tasks and environments would help show how far the selected result extends.
How the safety layer works
The task controller proposes a motion, and a safety filter can revise that command to satisfy a specified constraint. The SPARK toolkit provides configurable safety criteria, simulated tasks and an interface for hardware experiments.
Control barrier function theory describes safety as keeping the system inside a defined set of acceptable states. The guarantee requires a control action that can satisfy the rule under the model and available actuation. If the robot's state leaves no such action, the controller cannot enforce that rule at that state.
What happened on hardware
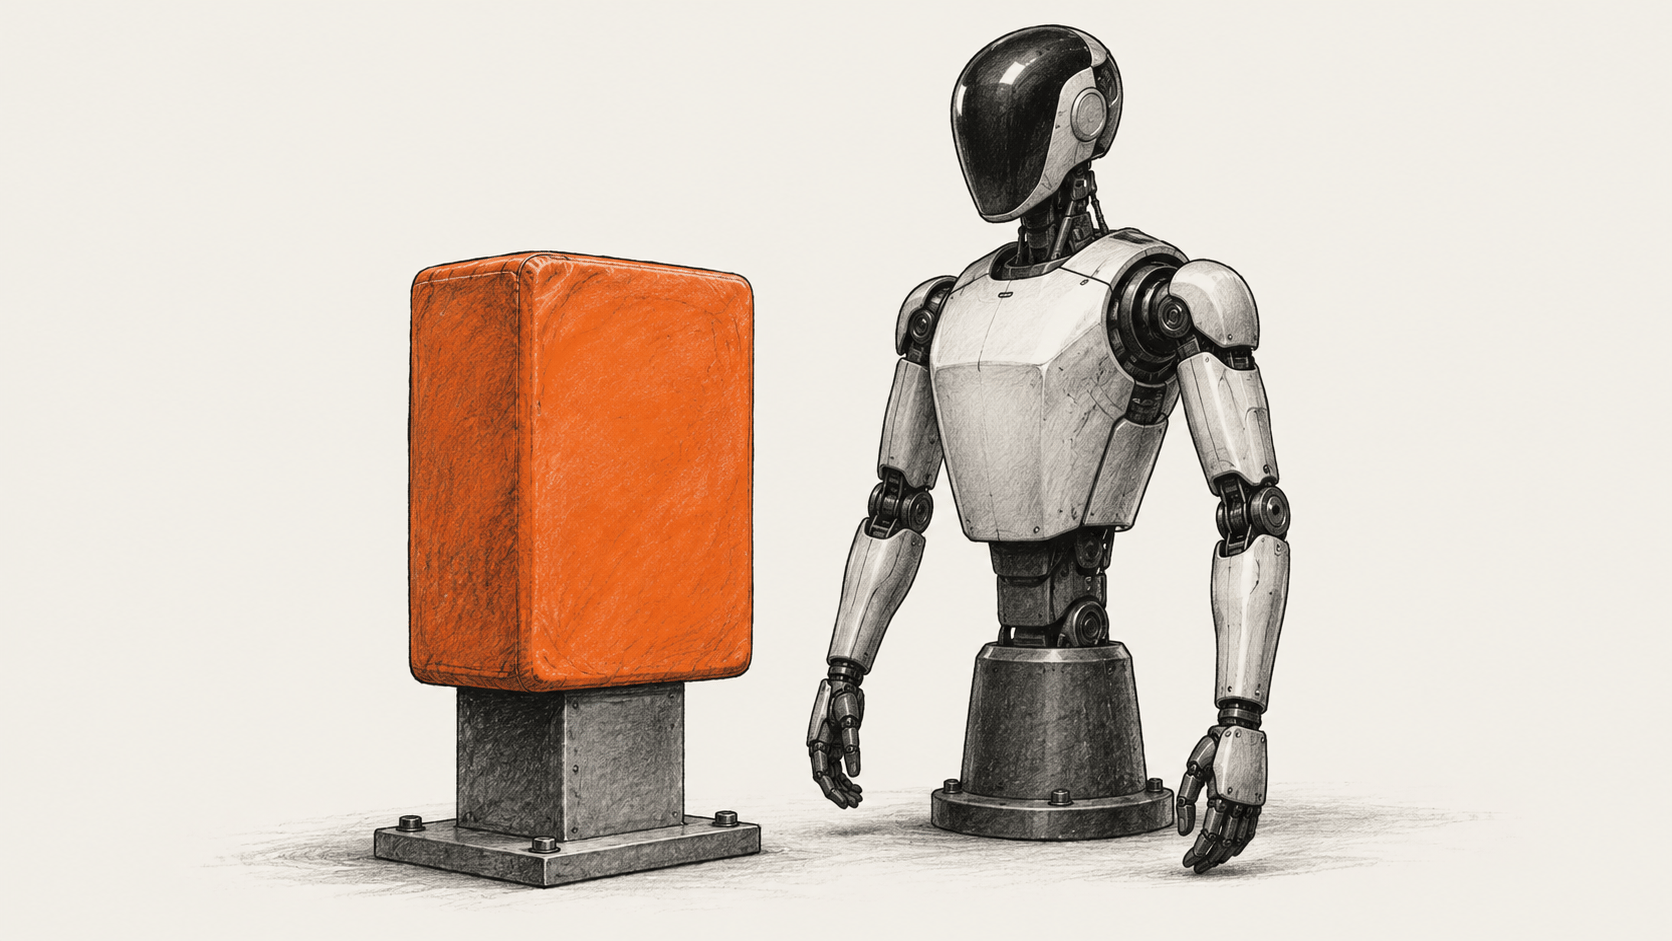
One selected upper-body, static-obstacle case per filter yielded a failure. In the illustrated trial, the arm cleared an obstacle without insertion, then contacted it on returning to the original target after an intermediate goal.
The physical tests exclude whole-body movement and moving obstacles. Selected failures cannot establish collision frequency in ordinary operation.
Where the broader numbers disagree
In simulation, the abstract says Siren found three times as many attacks as random search. Table 3 gives 3,277 versus 1,760 (1.86). Section 7.3 says 35 scenarios; its table uses 40. These conflicts remain unresolved.
An engineer can use this evidence to separate three questions: whether a controller's rule is sound under its assumptions, whether a safe correction remains feasible after a task change, and how often a real system reaches such a state. A stronger frequency estimate would require a specified sample of tasks and environments, with baseline and changed-task outcomes reported for each.
Sources & further reading
- Bao et al., Not an Accident: Physical trials and disputed numbers (v1).
- Ames and colleagues, Control Barrier Functions: Formal safety conditions and feasible control (2019).
- Sun and colleagues, SPARK: Toolkit and benchmark context (version 3, January 14, 2026).