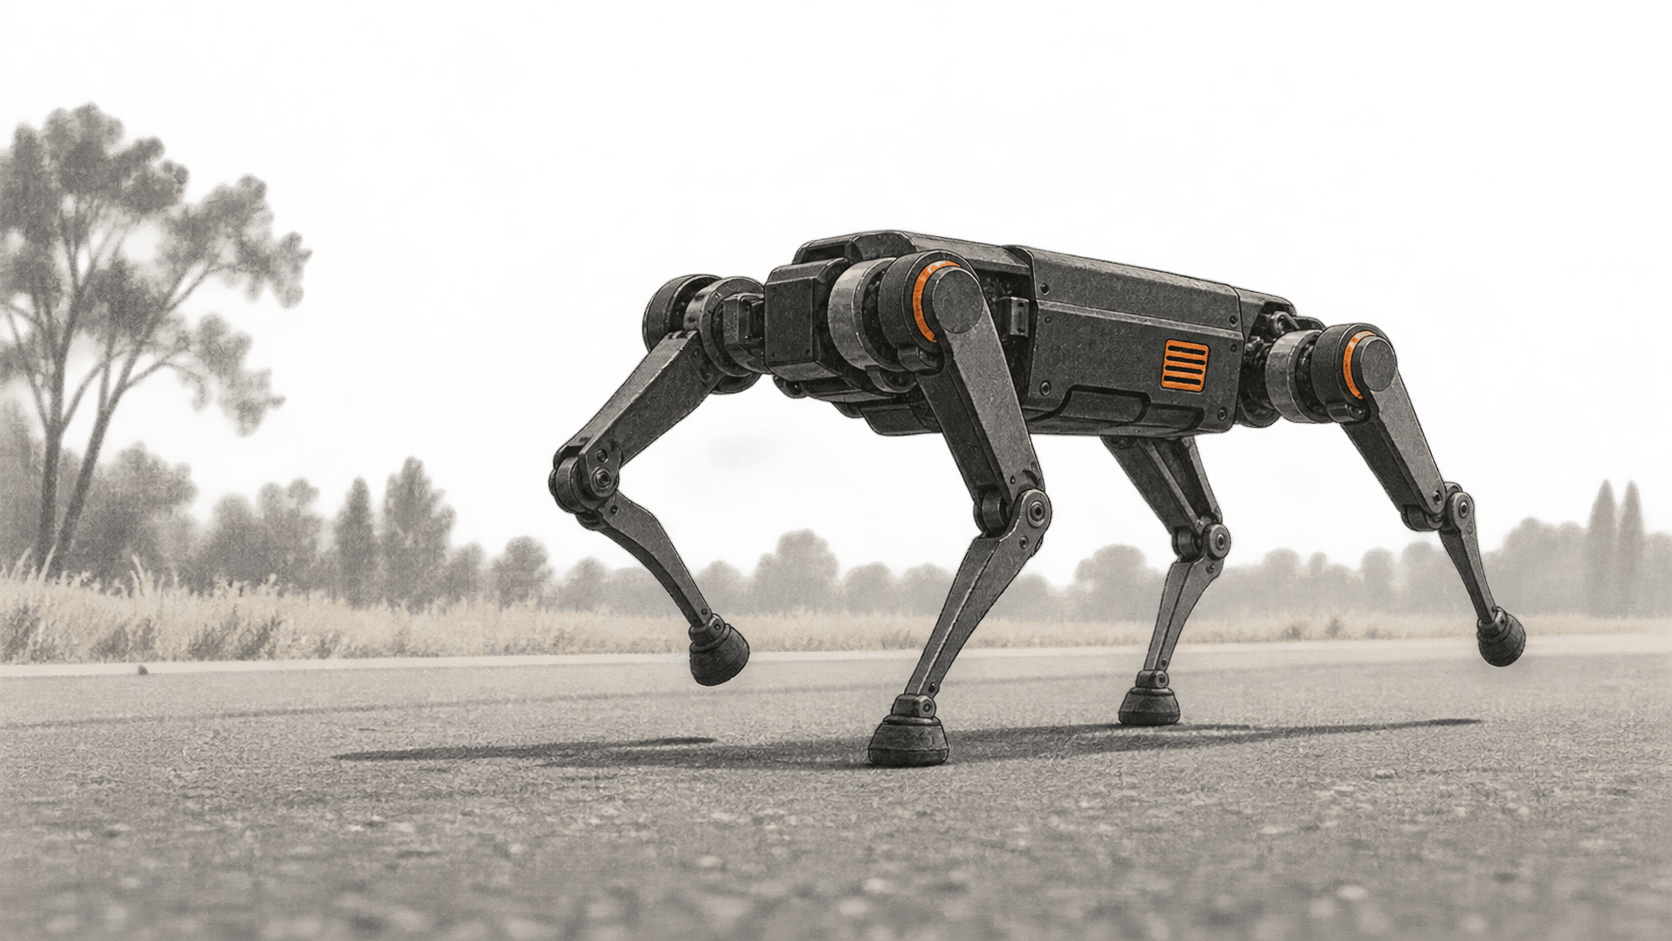
KAIST's four-legged RAIBO2 finished a 42.195-kilometer road marathon in South Korea in November 2024, taking 4 hours, 19 minutes and 52 seconds on one battery charge. The new development is a Nature paper published on September 23, 2026, which explains how its designers worked on the robot's legs, motor electronics and learned gait together to reduce energy loss.
The big change
- What changed: A peer-reviewed account now puts a long outdoor run alongside an energy-loss model for the whole quadruped. It gives robot designers more than a distance claim to examine: the ways motor heat, joint friction and foot impacts compete for the same battery charge.
- Why it matters: Operating range limits how long a mobile robot can work away from charging. RAIBO2 shows one route to extending that range through joint hardware and gait control designed together, though its marathon did not test a delivery or inspection workload.
- What to watch: The useful comparison for future quadrupeds is distance under a specified battery, speed, route and payload. The team's own comparison spreadsheet mixes measured and estimated figures, so a headline range alone cannot establish how another robot would perform on the same job.
The marathon result and its limits
The Nature paper reports a total cost of transport of 0.25 for RAIBO2. That measure relates energy used to the robot's weight and distance traveled. Its abstract compares the figure with a human reference value of 0.37. It also says the robot travels more than three times as far per charge as existing quadrupeds in the authors' comparison. Those are the authors' calculations and comparison set, not a universal ranking across identical field tasks.
The result took place on the 22nd Sangju Dried-Persimmon Marathon course, according to KAIST's November 17, 2024 release. KAIST described two climbs of roughly 50 meters near the 14- and 28-kilometer marks. An earlier KAIST release said the team's first race attempt in September 2024 ended at 37 kilometers when the battery ran out. The November finish therefore followed a failed attempt and design changes, including a larger battery.
The marathon demonstrated sustained locomotion around runners on a road course. KAIST said in 2024 that adding autonomous navigation was future work. Its reported campus test followed a GPS-guided path, but that does not establish that the robot chose its own route or handled delivery and patrol tasks during the marathon.
Saving energy at each step
The authors describe a linked design problem. Joint motors spend power holding the body up. Moving the legs also produces friction, while each foot landing can dissipate energy on contact. A stance or leg design that eases one loss can increase another. Their publicly available research preprint describes a lightweight leg, a low-ratio transmission and a motor-driving circuit built to reduce electrical resistance and switching loss. The Nature abstract identifies the same three design areas: mechanics, motor electronics and locomotion control.
The gait controller was trained with reinforcement learning in simulation. Its training rewards included slowing a foot just before it touched down and reducing current demand at the motors, according to the preprint. These measures address impact loss and motor heating. KAIST also said the joints can recover some energy on descents. None is a standalone explanation for the marathon distance; the reported gain comes from tuning the robot as a system.
What the range comparison can support
The final paper's supplementary comparison spreadsheet lists RAIBO2 at 43 kilograms, with a 1,447-watt-hour battery and a calculated range of about 52 kilometers. That range is an extrapolation in the table; the 42.195-kilometer race is the outdoor completion documented by the study. Several other robots' entries also rely on estimates or manufacturer specifications. The older public preprint used different battery and projected-range figures, so its numbers should not be substituted for the final supplement.
The same distinction applies to possible uses. A long run on a largely road-based course says something concrete about endurance and the team's engineering choices. It leaves questions about payload, repeated shifts, unscripted navigation, maintenance and difficult terrain for separate tests. KAIST's stated plans for navigation and disaster environments are research aims, not results of this marathon.
Sources & further reading
- Lee and colleagues, Nature, September 23, 2026. The peer-reviewed article's accessible abstract establishes the completion time, single-charge result, cost-of-transport figure and three-part design account. The publisher's public page exposes the abstract, figure captions and supplementary links; its main text was subscription restricted when checked on September 24, 2026.
- Nature supplementary comparison data, September 2026. The downloadable spreadsheet records robot mass, battery capacity, estimated range and comparison inputs. It distinguishes source values from estimates; the RAIBO2 range row is calculated, not a second outdoor run.
- KAIST, November 17, 2024. The institution's contemporary account gives the marathon distance, time and course, and says autonomous navigation was follow-up work. KAIST developed the robot, so claims of practical readiness remain the team's assessment.
- KAIST, November 15, 2024. Its pre-race account describes the unsuccessful September attempt, battery changes and a GPS-guided campus run. The campus distance and range projections are different tests from the November marathon.
- Lee and colleagues, Research Square preprint, 2025. The full public manuscript explains hardware and reinforcement-learning methods. It predates the final Nature version and contains different battery and projected-range values; the final paper and supplement govern those figures here.